robotics
Making robots learn from useful evidence, execute reliably, and work in the physical world.
My work connects robot learning with the practical systems around it: visual grounding, hand-motion annotation, policy diagnostics, command validation, and autonomous navigation.
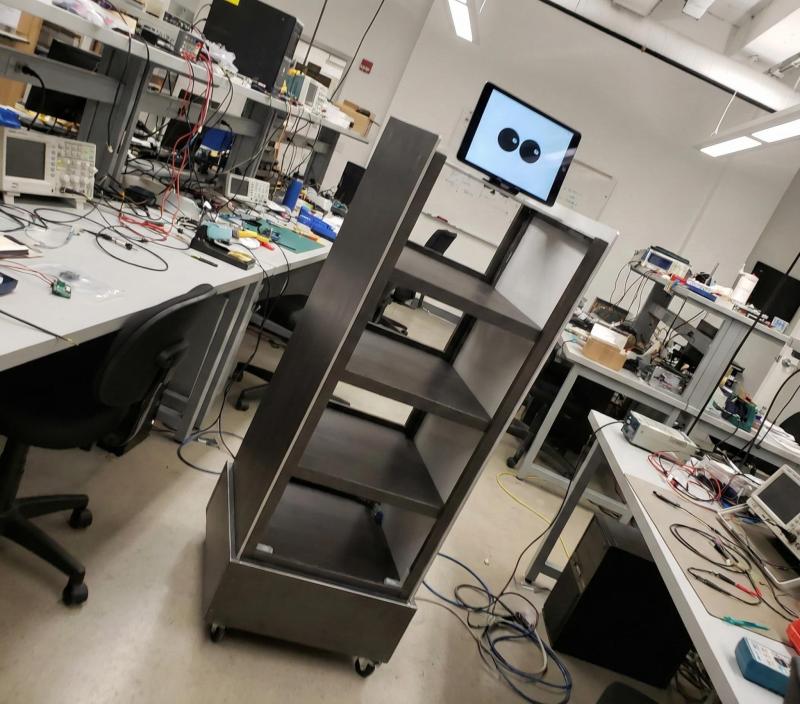
These projects range from research on imitation learning and robotic foundation models to correction tools for egocentric data and a food-runner robot built during my Accenture internship.