Yale University · optimization & kinematics
Turning target curves into working mechanisms
November – December 2025
I built an end-to-end pipeline that synthesizes planar four-bar linkages to trace target curves, including circles, ellipses, freehand shapes, and letters. It optimizes the mechanism geometry against a sampled reference trajectory and produces simulation-ready parameters.
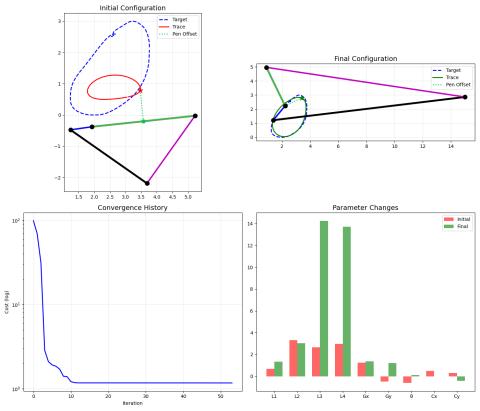
- Custom kinematic solver with branch selection and continuity tracking to avoid flips near singularities.
- Nine-parameter nonlinear least-squares formulation with both constrained and free pen placement.
- Levenberg–Marquardt optimizer built from scratch, using finite-difference Jacobians and stability controls.
- Tikhonov regularization and feasibility guards for compact, physically plausible mechanisms.
- Interactive predefined and user-drawn curves, with experiments on convergence, initialization, damping, and regularization.