Accenture · internship
From kitchen to table: an autonomous food-runner robot
May – September 2023
I built an autonomous food-runner robot and a connected ordering platform, bringing together the mechanical platform, embedded control, restaurant navigation, and the guest-facing ordering flow. The system delivered orders from the kitchen to tables and matched orders to guests in real time.
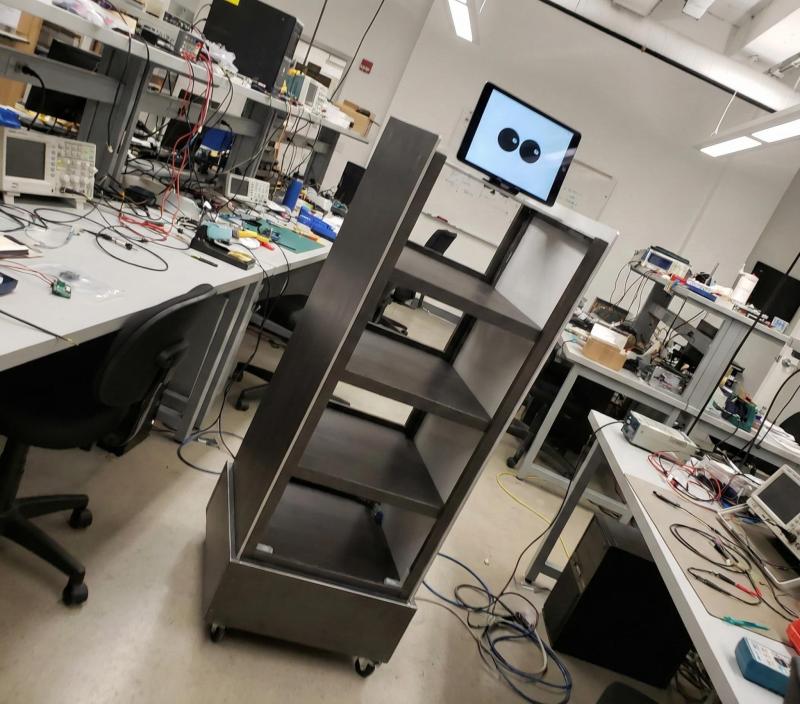
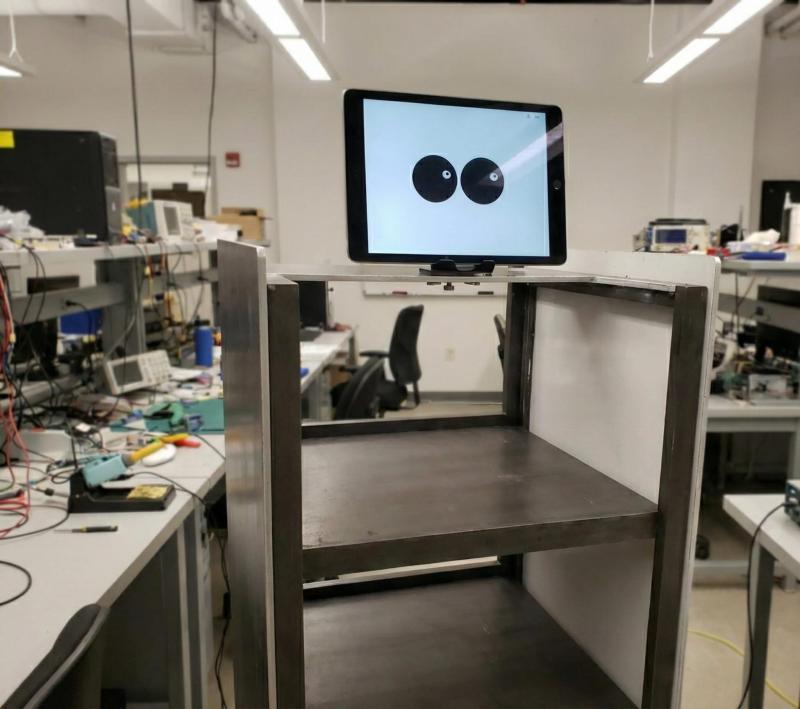
- SLAM-based mapping and localization for indoor navigation, designed for dynamic crowds and multi-floor operation.
- ROS on Raspberry Pi, integrating ultrasonic sensing and camera perception for obstacle detection.
- A* global path planning with finite state machines and behavior trees for pickup, delivery, rerouting, retries, and handoff.
- Full-stack ordering platform with a live menu, kitchen routing, and chatbot-based ordering.
- Table-side ordering and confirmations coordinated with the robot’s delivery tasks.